Autonomy software for the ROV fleet you already operate.
Developed over roughly a decade through Nauticus vehicle programs and field work, Nauticus ToolKITT™ brings practical autonomy into ROV workflows, starting with pilot assistance, repeatable execution, and software-assisted control. It helps operators improve consistency, reduce pilot workload, and build a path toward supervised autonomy and obstacle avoidance without replacing existing vehicles.
Upgrade ROV performance without replacing the fleet.
Pilot assistance
Focus autonomy where it helps first. Nauticus ToolKITT™ supports pilots with precise, software-assisted execution during repetitive and high-concentration subsea tasks.
Cleaner data. Faster deliverables.
More stable ROV execution helps capture consistent visual and survey data, reducing rework and simplifying post-processing.
Improve project margins
Repeatable control and more predictable execution help reduce non-productive time, protect fixed-price margins and standardize performance across crews.
Flexible autonomy beyond Aquanaut® Mk2.
Nauticus ToolKITT™ extends autonomy developed on Aquanaut® Mk2 into practical, modular ROV workflows that can grow as the vehicle, mission and operating model mature.
Vehicle agnostic
Deploy autonomy concepts across Nauticus platforms, legacy ROVs, observation-class systems, work-class fleets, AUVs and surface vehicles.
Flexible
Configure workflows around the mission, vehicle, sensor suite and operator environment.
Efficient and safe
Support repeatable execution, reduced pilot workload and more consistent operations across crews and conditions.
Modular
Add capability incrementally alongside existing control software to support pilot assistance, inspection workflows and supervised autonomy.
Obstacle avoidance
Develop supervised autonomy features that help vehicles detect and respond to obstacles as capability matures through integration and testing.
Software-assisted execution, from the surface.
The Nauticus ToolKITT™ interface gives crews situational awareness for planning, supervision and mission control. Define the survey area, set parameters, review vehicle state and adjust the mission as site conditions change.
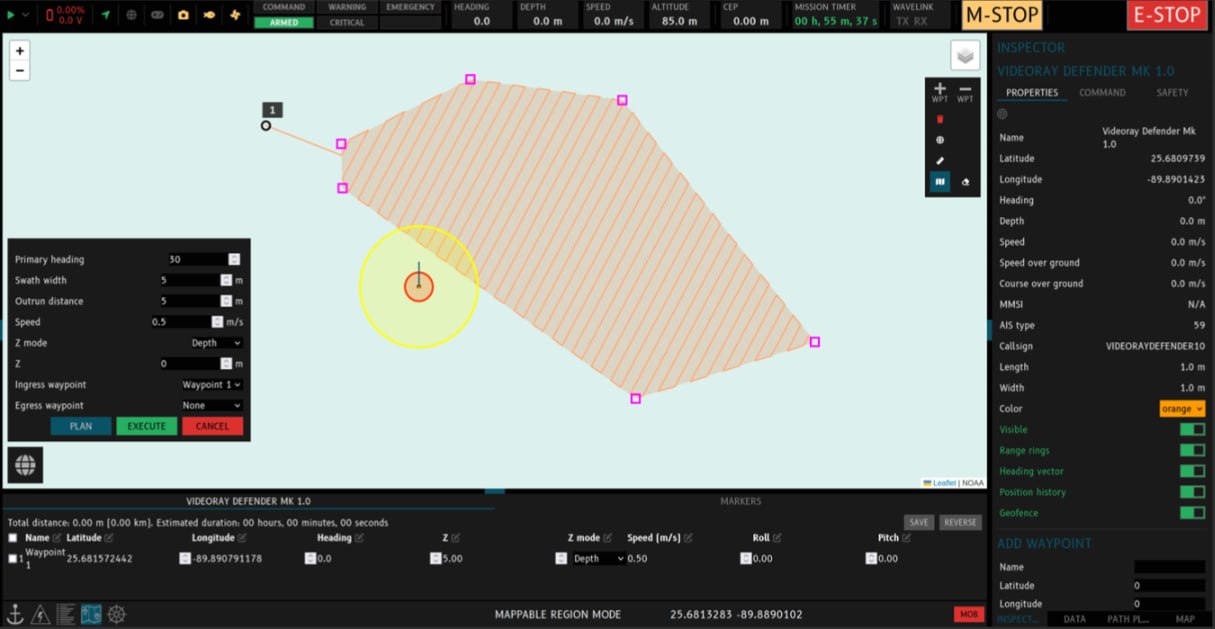
Nauticus ToolKITT™ running on a VideoRay Defender Mk 1.0. Mappable region mode: survey area defined, waypoints set, ready to execute.
One autonomy core. Your vehicles, or ours.
Nauticus ToolKITT™ is vehicle-agnostic and modular. It integrates alongside existing control software where supported by vehicle APIs, so operators can build on familiar workflows while adding software-assisted autonomy over time.
Running a different platform? Talk to our team about your vehicle.
More capable ROVs, stronger execution.
Win higher-value work
Differentiate with autonomy-enabled capability, repeatable execution and advanced inspection workflows.
Protect fixed-price margins
Improve consistency, reduce rework and make execution more predictable across survey and inspection scopes.
Standardize execution
Create repeatable workflows across pilots, shifts, vehicles and campaigns.
Reduce pilot workload
Support pilots during repetitive, high-concentration subsea tasks with software-assisted control.
Start integration now. Plan for delivery in early 2027.
Nauticus ToolKITT™ is structured as a licensed software product with topside integration. Start with practical pilot assistance and software-assisted control, then grow toward supervised autonomy and obstacle avoidance as integration and testing mature.
Current use
Used internally across Nauticus ROV and Aquanaut® Mk2 workflows.
Collaborative integration
Trial integration, testing and rollout with customer ROV fleets.
Productization path
Grow toward supervised autonomy and obstacle avoidance as capabilities mature through integration and testing.
Built by subsea operators and robotics engineers.
Nauticus brings subsea operating experience, autonomy developed on Aquanaut® Mk2 and practical field integration into one software path for existing ROV fleets.
- Used across Nauticus ROV and Aquanaut® Mk2 workflows
- Practical integration path for existing ROV fleets
- Software-assisted control that sits alongside familiar workflows
- Phased rollout from pilot assistance to supervised autonomy
Supervised autonomy for real ROV workflows.
Your crew moves from constant hand-flying toward software-assisted supervision. The same fleet becomes more consistent, more repeatable and better positioned for higher-value inspection and survey scopes.
- Licensed software with topside integration
- Pilot assistance and software-assisted control
- Supervised autonomy roadmap
- Obstacle avoidance in development
When precision saves vessel days.
Depending on the specific task, Nauticus has seen time savings of up to 30% through more precise, repeatable software-assisted flying.
To show what that can mean commercially, use a simple model: 200 planned ROV operating days at an assumed full-spread day rate of about $60,000, including the vessel.
A more conservative average 20% time reduction in that model turns 200 operating days into 160. That is 40 vessel days saved or redeployed, representing about $2.4 million of modeled execution cost removed or capacity recovered.
On fixed-price work, saved vessel days can materially improve project margin because the contract value stays fixed while execution cost comes down.
Actual savings depend on the task, vehicle, crew, site conditions and integration path.
Illustrative model only. Based on 200 planned operating days × 20% time reduction at a full-spread day rate that includes the vessel. Results vary by task, vehicle, crew, site and integration.
Upgrade ROV performance without replacing the fleet.
Talk with Nauticus about applying Nauticus ToolKITT™ to your ROV fleet, or building a phased integration path across ROVs, AUVs and surface vehicles.
Talk with Nauticus